Welcome to the Pycom forum Forum
    • \[\[global:header.categories\]\]
    • \[\[global:header.recent\]\]
    • \[\[global:header.tags\]\]
    • \[\[global:header.popular\]\]
    • Login

    Explore Pybytes | Official Documentation | Report a Firmware Bug/Issue | GitHub

    Function similar to Pulse In in C

    Scheduled Pinned Locked Moved LoPy
    lopyerror
    27 Posts 4 Posters 9.1k Views 4 Watching
    Loading More Posts
    • Oldest to Newest
    • Newest to Oldest
    • Most Votes
    Reply
    • Reply as topic
    Log in to reply
    This topic has been deleted. Only users with topic management privileges can see it.
    • D Offline
      Devang Sharma
      last edited by

      @livius It really depends on the period window of the particular sensor. Generally it is in milliseconds, while the timeout parameter in pycom.pulses_get() is in microseconds. So it should be set higher. But it may not be able to detect larger pulse widths(in ms).( I don't know the exact amount though)

      robert-hhR 1 Reply Last reply Reply Quote 0
      • robert-hhR Offline
        robert-hh @Devang Sharma
        last edited by

        @devang-sharma pycom.pulses_get() uses the RMT unit of the ESP32, and AFAIK this has 15 bit registers for a pulse width. Therefore the maximum pulse length it can detect is about 32 ms, which I expect to be the largest timeout.

        1 Reply Last reply Reply Quote 1
        • sorenS Offline
          soren @livius
          last edited by

          @livius the problem with pycom.pulses_get is that it returns a list of pulses. Arduino's "pulsein" just returns the elapsed time in ms from one single transition - and that is what I need..

          But I don't know, maybe I would have to just pick out the first 2 elements in the list ?

          1 Reply Last reply Reply Quote 0
          • sorenS Offline
            soren @livius
            last edited by

            @livius I tried using pulses_get now, and realized that it's actually pretty perfect (in theory) for my purpose. Problem is though, now after trying it out, it seems very random if it wants to give me pulses or not. Most of the times it will just return an empty array, and then suddenly it will give loads of data. Sometimes it seems to have an impact if I switch s0 low to high on the tcs3200 http://image.dfrobot.com/image/data/SEN0101/TCS3200 TCS3210.pdf but surely, this should not affect the pulses that I'm reading from the "out" pin on the tsc3200...

            L robert-hhR 2 Replies Last reply Reply Quote 1
            • L Offline
              livius @soren
              last edited by

              @soren
              i have not clue why it not work, and i have not this sensor to test it self.

              #i have upvoted you, you can now send messages without long delay

              think about people first, then computers

              1 Reply Last reply Reply Quote 0
              • robert-hhR Offline
                robert-hh @soren
                last edited by

                @soren Lookijng at the data sheet, it seems that the device is sensing a constant frequency when activated. That confuses pulses_get, since it finishes after a timeout, which may never happen. You can fore that timeout by pulling /OE of the device high, but that has to be done in a timer ISR. So the test sequence would be:

                start timer ISR (like 1 ms) with as handler, that sets /OE high
                pull /OE low
                start pulses_get() with a timeout of that timer ISR

                When pulses_get() returns, the timer has been triggered, and you should have an array of pulses. The first one may be a short pulse, but the next ones should have consistent values.

                sorenS 1 Reply Last reply Reply Quote 1
                • sorenS Offline
                  soren @robert-hh
                  last edited by

                  @robert-hh aah yes that is a very good observation robert, thank you. did not see that.

                  it seems to be working now. here's my code:

                  class OETIMER: # oe timer, sets oe pin high after 1 ms
                      def __init__(self):
                          self.__alarm = Timer.Alarm(self.setOEHighHandler, ms=1, periodic=False)
                  
                      def setOEHighHandler(self, alarm):
                          oe.value(1)
                  

                  I then set frequency rate to 20% by setting s0 high and s1 low. Then, doing exactly what you mentioned Robert, doesn't quite work. I need to set oe low as the first thing, then start my timer and at last read pulses. Like so:

                  oe.value(0)
                  oeTimer = OETIMER()
                  pulses_get(sout, 1)
                  
                  robert-hhR 2 Replies Last reply Reply Quote 0
                  • robert-hhR Offline
                    robert-hh @soren
                    last edited by

                    @soren That's OK. Since the timeout you've chose is pretty short, the sequence of statement is critical. The method using pulses_get() is not optimal, as you said, since you need just a few pulses, and not many. At least, there seems not to be an overflow risk, since the underlying call uses a ringbuffer, and the length of the returned list is limited to 128 values. Please consider, that the timeout is to be given in µs. So pulses_get(sout, 1) of your example below uses a timeout of 1 µs.

                    1 Reply Last reply Reply Quote 0
                    • robert-hhR Offline
                      robert-hh @soren
                      last edited by

                      @soren Testing with a frequency generator, square wave, I found a bug in pulses_get. If you go down below 25 Hz (= 20000us pulse duration), the pulse counter locks. Even raising the frequency again does not help, only hard reset. 26Hz is the slowest you can take. looking at the light sensor, this is bad, because the dark frequency is at about 10 Hz.
                      That behavior can be cured by changing the source code, mods/modpycom.c, line 107, into:
                      rmt_rx.rx_config.idle_threshold = 0xffff;
                      Then, the maximum timeout value is about 65000, the lowest frequency with reasonable values is 16 Hz (or 32 ms pulse duration). Going below that gives you bad values, but once you're above that threshold, the device works again as expected without the need for a reset.

                      sorenS D 2 Replies Last reply Reply Quote 2
                      • sorenS Offline
                        soren @robert-hh
                        last edited by soren

                        @robert-hh

                        Very good to know! I doubt this sensor will go down into frequencies that low though. And actually, getting many samples from pulses_get is pretty neat since I need to get an average value anyway. So, so far I'm very optimistic. Still some way to completely getting correct results and understanding them.
                        And thanks for the microseconds tip, obviously pulses_get timeout should be 1000 then.

                        Here's a snippet of my data output. This is with red filter activated (s2 and s3 held low). Bold values are before I put a completely red book over the sensor (very close):
                        305.0
                        345.0
                        305.875
                        308.625
                        311.25
                        296.1667
                        291.1666

                        208.2
                        201.9
                        206.7
                        206.2
                        209.6
                        196.1
                        179.0

                        Strange thing is how the values go down after putting the red book over. Maybe it's inverse. I'll probably have to read more up on the concepts of it to get it. Currently trying to grasp this: https://arduinoplusplus.wordpress.com/2015/07/15/tcs230tcs3200-sensor-calibration/ not

                        EDIT: aaah, just realised that the data looks fine. As a period gets shorter, obviously frequency gets higher. Shoot me.

                        Code:

                        while True:
                            oe.value(0)
                            oeTimer = OETIMER()
                            data = pulses_get(sout, 1000)
                            del data[-1] # delete last element
                            del data[0] # delete first element
                            sum = 0
                            for trans in data:
                                sum += trans[1]
                            avr = sum / len(data)
                            print(avr)
                            time.sleep(1)
                        

                        EDIT II:
                        Hmm, after converting from period to frequency, I still get some strange results. Eg, when holding up a (very) red book - the sensor will read RGB frequencies like this one: [3086.42, 6038.647, 3100.775] This is in hertz, and I found it weird that the red channel isn't relatively higher than the other ones. I'm doing calculation and conversion like this:

                        s2Array = [0, 0, 1] # arrays for setting color filters on sensor
                        s3Array = [0, 1, 1]
                        while True:
                            rgbArray = [0, 0, 0]
                            for num in range(0, 3):
                                s2.value(s2Array[num]) # set colour filters
                                s3.value(s3Array[num])
                                time.sleep_ms(1)
                                oe.value(0)
                                oeTimer = OETIMER() # set timer to turn off sensor
                                data = pulses_get(sout, 1000) # get period values
                                if len(data) == 0:
                                    print('no data collected. breaking.')
                                    break
                                del data[-1] # delete last element
                                del data[0] # delete first element
                                sum = 0
                                for trans in data:
                                    sum += trans[1]
                                avrPeriodUs = sum / len(data) # average period in micro seconds
                                avrPeriodSec = avrPeriodUs / 1000000 # convert to seconds
                                avrFreq = 1 / avrPeriodSec # get frequency
                                #print(num, ' ', avrFreq)
                                rgbArray[num] = avrFreq
                                time.sleep(1)
                            print(rgbArray)
                        
                        1 Reply Last reply Reply Quote 0
                        • D Offline
                          Devang Sharma @robert-hh
                          last edited by

                          @robert-hh As you mentioned about the changes made in modpycom.c, does it mean that pulses_get() can be used for PWM of more than 32ms??

                          Thanks,
                          Devang

                          robert-hhR 1 Reply Last reply Reply Quote 0
                          • robert-hhR Offline
                            robert-hh @Devang Sharma
                            last edited by robert-hh

                            @devang-sharma No. pulses_get() uses 16 bit counters of a 1 MHz clock. The high bit is ignored, so you get effectively results only for pulses shorter than 32ms. The change only prevents, that the counter stalls if by chance longer pulses arrive. I did not dig further yet to see, if the counter can be set to lower input frequencies. But since pulses_get uses the remote control circuit, intended for signal frequencies of 20-50 kHz, the chances may be odd.

                            1 Reply Last reply Reply Quote 1
                            • D Offline
                              Devang Sharma
                              last edited by

                              @robert-hh,
                              I've been trying to write a code which can function as pulses_get() but can detect higher pulse width. I used Nova SDS011 Dust sensor.

                              This is my main.py file:

                              from trig import *
                              import time
                              from machine import Pin
                              from machine import Timer
                              trig = TRIG()
                              chrono = Timer.Chrono()
                              chrono.start()
                              
                              while True:
                              
                                  if pin1() == 1:
                                      trig.high1()
                                  if pin2() == 1:
                                      trig.high2()
                              

                              This is my library file trig.py:

                              import time
                              from machine import Pin
                              from machine import PWM
                              
                              pin1 = Pin("G9", mode = Pin.IN, pull = Pin.PULL_UP) # PM2.5
                              pin2 = Pin("G8", mode = Pin.IN, pull = Pin.PULL_UP) # PM10
                              
                              class TRIG:
                                  def __init__(self, prev1=0, prev2=0, pulse1=0, pulse2=0, dust25=0.0, dust10=0.0):
                                      self.prev1 = prev1
                                      self.prev2 = prev2
                                      self.pulse1 = pulse1
                                      self.pulse2 = pulse2
                                      self.dust25 = dust25
                                      self.dust10 = dust10
                              
                                  def low1(self):
                                      if pin1.value() == 1:
                                          self.high1()
                                      self.pulse1 = time.ticks_diff(self.prev1, time.ticks_us())
                                      print("Pulse1: ", self.pulse1)
                              
                                  def low2(self):
                                      if pin2.value() == 1:
                                          self.high2()
                                      self.pulse2 = time.ticks_diff(self.prev2, time.ticks_us())
                                      print("Pulse2: ", self.pulse2)
                              
                                  def high1(self):
                                      if pin1.value() == 0:
                                          self.low1()
                                      self.prev1 = time.ticks_us()
                              
                                  def high2(self):
                                      if pin2.value() == 0:
                                          self.low2()
                                      self.prev2 = time.ticks_us()
                              
                                  def getdata(self):
                                      if self.pulse1 >= 2000:
                                          self.dust25 = float((self.pulse1 - 2000)/1000)
                              
                                      if self.pulse2 >= 2000:
                                          self.dust10 = float((self.pulse2 - 2000)/1000)
                              
                                      print("DUST PM2.5: ", self.dust25)
                                      time.sleep_us(500)
                                      print("DUST PM10 : ", self.dust10)
                                      time.sleep_us(500)
                              

                              Right now, I'm not calling getdata() function. I'm only trying to measure pulse width. While doing that, I get the output as below:
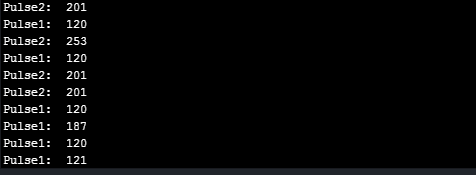
                              0_1516261967903_output.png

                              This received output is in Microseconds. That means that the frequencies are around 4-5kHz. Received data is either wrong or again this is some of the limitations of LoPy! I'm confused! What is the issue here? Is there any solution?

                              Also, I've read about time.ticks_diff() in docs, which says:

                              Measure period between consecutive calls to ticksms(), ticks_us(), or ticks_cpu(). The value returned by these functions may wrap around at any time, so directly subtracting them is not supported. ticks_diff() should be used instead. “old” value should actually precede “new” value in time, or result is undefined. This function should not be used to measure arbitrarily long periods of time (because ticks() functions wrap around and usually would have short period).

                              Does this also say about the limitations?

                              Thanks,
                              Devang

                              robert-hhR 1 Reply Last reply Reply Quote 0
                              • robert-hhR Offline
                                robert-hh @Devang Sharma
                                last edited by

                                @devang-sharma Ticks_us uses a 32 bit counter, which starts after reset and wraps around after 2**32 microseconds or about 71 minutes. But there is a bug in ticks_diff(), such that about 36 minutes after reset numbers received from tick_us() will raise an exception when fed into tick_diff(). But since you do not get an exception, this should not be your problem. I glanced at your code, but I'm wondring why you do not use the edge triggered interrupts of the PIN handler by pin.callback(trigger, handler=None, arg=None). Use that to
                                a) register a pair of handlers for rising and falling events,
                                b) memorize the time at a rising edge, set a busy flag and
                                c) get the difference at a falling edge, put it into a place for results, e.g. a list, and clear the busy flag.
                                or the like. Synchronization may be a little bit tricky.
                                Pitfalls:
                                a) There is a latency of a few 100 µs for all kind of interrupts. That will have an impact at low readings.
                                b) The esp32 might create false triggers if the slope of the input signal is too slow. The datasheet is silent about that. So you might have to double check in your code in the handler, is the state is as expected, e.g. if after a falling slope the level is indeed low.

                                L D 2 Replies Last reply Reply Quote 1
                                • L Offline
                                  livius @robert-hh
                                  last edited by

                                  @robert-hh said in Function similar to Pulse In in C:

                                  But there is a bug in ticks_diff(), such that about 36 minutes after reset numbers received from tick_us() will raise an exception when fed into tick_diff()

                                  because it cast to small int and i do not understand the comment that this is "as designed cast"

                                  STATIC mp_obj_t time_ticks_diff(mp_obj_t t0, mp_obj_t t1) {
                                      // We want to "cast" the 32 bit unsigned into a 30-bit small-int
                                      uint32_t start = mp_obj_get_int(t0);
                                      uint32_t end = mp_obj_get_int(t1);
                                      return MP_OBJ_NEW_SMALL_INT((end - start) & MP_SMALL_INT_POSITIVE_MASK);
                                  }
                                  

                                  think about people first, then computers

                                  robert-hhR 1 Reply Last reply Reply Quote 0
                                  • D Offline
                                    Devang Sharma @robert-hh
                                    last edited by Devang Sharma

                                    @robert-hh Thanks for the help. I tried using pin.callback().

                                    main.py :

                                    from trig import *
                                    import time
                                    from machine import Pin
                                    from machine import Timer
                                    trig = TRIG()
                                    chrono = Timer.Chrono()
                                    chrono.start()
                                    
                                    while True:
                                    
                                        # if pin1() == 1:
                                        #     trig.high1()
                                        # if pin2() == 1:
                                        #     trig.high2()
                                    
                                        # if int(chrono.read()) >= 60:
                                        #     trig.getdata()
                                        time.sleep_ms(500)
                                        pin1.callback(Pin.IRQ_RISING, trig.high1())
                                        time.sleep_ms(500)
                                        pin2.callback(Pin.IRQ_RISING, trig.high2())
                                    

                                    trig.py :

                                    import time
                                    from machine import Pin
                                    from machine import PWM
                                    
                                    pin1 = Pin("G9", mode = Pin.IN, pull = Pin.PULL_UP) # PM2.5
                                    pin2 = Pin("G8", mode = Pin.IN, pull = Pin.PULL_UP) # PM10
                                    
                                    class TRIG:
                                        def __init__(self,flag1=0, flag2=0, prev1=0, prev2=0, pulse1=0, pulse2=0, dust25=0.0, dust10=0.0):
                                            self.flag1 = flag1
                                            self.flag2 = flag2
                                            self.prev1 = prev1
                                            self.prev2 = prev2
                                            self.pulse1 = pulse1
                                            self.pulse2 = pulse2
                                            self.dust25 = dust25
                                            self.dust10 = dust10
                                    
                                        def low1(self):
                                            # pin1.callback(Pin.IRQ_RISING, self.high1())
                                            # if pin1.value() == 1:
                                            #     self.high1()
                                            if self.flag1 == 1:
                                                self.pulse1 = time.ticks_diff(self.prev1, time.ticks_us())
                                                print("Pulse1: ", self.pulse1)
                                                self.flag1 = 0
                                            # self.getdata()
                                    
                                        def low2(self):
                                            # pin2.callbck(Pin.IRQ_RISING, self.high2())
                                            # if pin2.value() == 1:
                                            #     self.high2()
                                            if self.flag2 == 1:
                                                self.pulse2 = time.ticks_diff(self.prev2, time.ticks_us())
                                                print("Pulse2: ", self.pulse2)
                                                self.flag2 = 0
                                            # self.getdata()
                                    
                                        def high1(self):
                                            self.prev1 = time.ticks_us()
                                            self.flag1 = 1
                                            pin1.callback(Pin.IRQ_FALLING, self.low1())
                                            # if pin1.value() == 0:
                                            #     self.low1()
                                    
                                        def high2(self):
                                            self.prev2 = time.ticks_us()
                                            self.flag2 = 1
                                            pin2.callback(Pin.IRQ_FALLING, self.low2())
                                            # if pin2.value() == 0:
                                            #     self.low2()
                                    
                                    
                                        def getdata(self):
                                            if self.pulse1 >= 2000:
                                                self.dust25 = float((self.pulse1 - 2000)/1000)
                                    
                                            if self.pulse2 >= 2000:
                                                self.dust10 = float((self.pulse2 - 2000)/1000)
                                    
                                            print("DUST PM2.5: ", self.dust25)
                                            time.sleep_us(500)
                                            print("DUST PM10 : ", self.dust10)
                                            time.sleep_us(500)
                                    

                                    Output:

                                    Pulse1: 120
                                    Pulse2: 106
                                    Pulse1: 107
                                    Pulse2: 106
                                    Pulse1: 93
                                    Pulse2: 93
                                    Pulse1: 107
                                    Pulse2: 120
                                    Pulse1: 106
                                    Pulse2: 93
                                    Pulse1: 94
                                    Pulse2: 107
                                    Pulse1: 107
                                    Pulse2: 106
                                    Pulse1: 107
                                    Pulse2: 106

                                    Why I get so short pulses?

                                    robert-hhR 2 Replies Last reply Reply Quote 0
                                    • robert-hhR Offline
                                      robert-hh @livius
                                      last edited by

                                      @livius The snippet you show is not used by utime.ticks_diff(). The one used is in esp32/mods/modutime.c

                                      STATIC mp_obj_t time_ticks_diff(mp_obj_t start_in, mp_obj_t end_in) {
                                         uint32_t start = mp_obj_get_int(start_in);
                                         uint32_t end = mp_obj_get_int(end_in);
                                         return mp_obj_new_int_from_uint((end - start));
                                      }
                                      STATIC MP_DEFINE_CONST_FUN_OBJ_2(time_ticks_diff_obj, time_ticks_diff);
                                      

                                      The problem is, that tick_us() returns unsigned 32 bit values, which do not fit into a short int and fail in ticks_diff() when they should be converted to an int. There are implementations of the functions in extmod/mphal_utime.c, which work. Alternatively, I use the following patch for ticks_diff()

                                      STATIC mp_obj_t time_ticks_diff(mp_obj_t start_in, mp_obj_t end_in) {
                                          int32_t start = mp_obj_get_int_truncated(start_in);
                                          int32_t end = mp_obj_get_int_truncated(end_in);
                                          return mp_obj_new_int((end - start));
                                      }
                                      STATIC MP_DEFINE_CONST_FUN_OBJ_2(time_ticks_diff_obj, time_ticks_diff);
                                      

                                      Which takes just the lower bits of the int. That would even allow ticks_us and tick_ms to return 64 bit values, reducing the chance of an overflow substantially (overflow of tick_us() after about 584542 years).

                                      L 1 Reply Last reply Reply Quote 0
                                      • robert-hhR Offline
                                        robert-hh @Devang Sharma
                                        last edited by

                                        @devang-sharma I'll look into that tonight. I need a test set-up for that.

                                        1 Reply Last reply Reply Quote 1
                                        • L Offline
                                          livius @robert-hh
                                          last edited by

                                          @robert-hh
                                          Yes, i digged in wrong place..

                                          think about people first, then computers

                                          1 Reply Last reply Reply Quote 0
                                          • robert-hhR Offline
                                            robert-hh @Devang Sharma
                                            last edited by

                                            @devang-sharma I got a little bit lost by your code, so I made one by myself, which works at least with the function generator. The times shown ar a little bit shorter than what I set-up at the function generator, like 899 instead of 900, but mostly right.

                                            #
                                            import machine
                                            import utime
                                            
                                            class Pulses:
                                                def __init__(self, p10_name, p25_name):
                                                    self.result_p10 = None
                                                    self.result_p25 = None
                                                    self.start_p10 = None
                                                    self.start_p25 = None
                                                    if p10_name is not None:
                                                        self.pin_p10 = machine.Pin(p10_name, machine.Pin.IN, pull = machine.Pin.PULL_UP)
                                                        self.pin_p10.callback(machine.Pin.IRQ_RISING | machine.Pin.IRQ_FALLING, self.trig_p10)
                                                    if p25_name is not None:
                                                        self.pin_p25 = machine.Pin(p25_name, machine.Pin.IN, pull = machine.Pin.PULL_UP)
                                                        self.pin_p25.callback(machine.Pin.IRQ_RISING | machine.Pin.IRQ_FALLING, self.trig_p25)
                                            
                                                def trig_p10(self, pin):
                                                    if self.pin_p10.value() == 1:
                                                        self.start_p10 = utime.ticks_us()
                                                    elif self.start_p10 is not None:
                                                        self.result_p10 = utime.ticks_diff(self.start_p10, utime.ticks_us())
                                                        self.start_p10 = None
                                            
                                                def trig_p25(self, pin):
                                                    if self.pin_p25.value() == 1:
                                                        self.start_p25 = utime.ticks_us()
                                                    elif self.start_p25 is not None:
                                                        self.result_p25 = utime.ticks_diff(self.start_p25, utime.ticks_us())
                                                        self.start_p25 = None
                                            
                                                def get_p10(self):
                                                    if self.result_p10 is None:
                                                        return None
                                                    else:
                                                        result = self.result_p10
                                                        self.result_p10 = None
                                                        return result
                                            
                                                def get_p25(self):
                                                    if self.result_p25 is None:
                                                        return None
                                                    else:
                                                        result = self.result_p25
                                                        self.result_p25 = None
                                                        return result
                                            
                                                def stop(self):
                                                    self.pin_p10.callback(machine.Pin.IRQ_RISING | machine.Pin.IRQ_FALLING, None)
                                                    self.pin_p25.callback(machine.Pin.IRQ_RISING | machine.Pin.IRQ_FALLING, None)
                                            #
                                            #
                                            pulses = Pulses("G9", "G8")
                                            try:
                                                while True:
                                                    res = pulses.get_p10()
                                                    if res is not None:
                                                        print ("DUST PM10:  {:<6.1f}".format(res/1000))
                                                    res = pulses.get_p25()
                                                    if res is not None:
                                                        print ("DUST PM2.5: {:<6.1f}".format(res/1000))
                                                    utime.sleep_ms(10)
                                            except KeyboardInterrupt:
                                                pulses.stop()
                                                print ("Test stopped")

                                            
                                            D 1 Reply Last reply Reply Quote 1

                                            Hello! It looks like you're interested in this conversation, but you don't have an account yet.

                                            Getting fed up of having to scroll through the same posts each visit? When you register for an account, you'll always come back to exactly where you were before, and choose to be notified of new replies (either via email, or push notification). You'll also be able to save bookmarks and upvote posts to show your appreciation to other community members.

                                            With your input, this post could be even better 💗

                                            Register Login
                                            • 1
                                            • 2
                                            • 1 / 2
                                            • First post
                                              Last post

                                            Pycom on Twitter

                                            Pycom