Unhandled exception in callback handler
-
from machine import UART
import time
from network import Bluetooth
import adafruit_gps
import pycom
import _thread
def parse_and_broadcast():
    while True:
        gps.update()

        if not gps.has_fix:
            print('Waiting for fix...')
            continue
        print('=' * 40)  # Print a separator line.
        print('Latitude: {} degrees'.format(gps.latitude))
        print('Longitude: {} degrees'.format(gps.longitude))
        print('Fix quality: {}'.format(gps.fix_quality))
        latitude = gps.latitude
        longitude = gps.longitude
        latlong = latitude + longitude
        print("latlong:",latlong)
        chr1.value(latlong)


            #if gps.satellites is not None:
                #print('# satellites: {}'.format(gps.satellites))
            #if gps.altitude_m is not None:
                #print('Altitude: {} meters'.format(gps.altitude_m))
            #if gps.track_angle_deg is not None:
                #print('Speed: {} knots'.format(gps.speed_knots))
            #if gps.track_angle_deg is not None:
                #print('Track angle: {} degrees'.format(gps.track_angle_deg))
            #if gps.horizontal_dilution is not None:
                #print('Horizontal dilution: {}'.format(gps.horizontal_dilution))
            #if gps.height_geoid is not None:
                #print('Height geo ID: {} meters'.format(gps.height_geoid))


def conn_cb (bt_o):
    events = bt_o.events()
    if  events & Bluetooth.CLIENT_CONNECTED:
        print("Client connected")
    elif events & Bluetooth.CLIENT_DISCONNECTED:
        print("Client disconnected")


def char1_cb(chr,arg1=None):
    events = chr.events()
    if events &  Bluetooth.CHAR_READ_EVENT :
        parse_and_broadcast()
uart = UART(1, baudrate=115200, pins=('P8','P4'))    #tx rx
gps = adafruit_gps.GPS(uart)
print('Advertising Bluetooth...')
bluetooth = Bluetooth()
bluetooth.advertise(True)
bluetooth.set_advertisement(name='gps', service_uuid=b'1234567890abcdef')
srv1 = bluetooth.service(uuid='0000000000000000', isprimary=True)
chr1 = srv1.characteristic(uuid='0000000000000002', properties=Bluetooth.PROP_INDICATE | Bluetooth.PROP_BROADCAST | Bluetooth.PROP_READ | Bluetooth.PROP_WRITE| Bluetooth.PROP_NOTIFY, value='InitialValue')
bluetooth.callback(trigger=Bluetooth.CLIENT_CONNECTED | Bluetooth.CLIENT_DISCONNECTED, handler=conn_cb)
chr1.callback(trigger=Bluetooth.CHAR_READ_EVENT | Bluetooth.CHAR_NOTIFY_EVENT, handler=char1_cb)
I am using fipy over pysense. I connected external gps. I am reading on uart. I parse. I broadcast the data over ble to the terminal application. after a while I get an error from ble as below
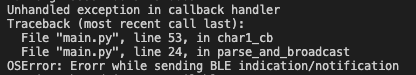
How can ı fix this error?
Do you have any ideas guys?
Can you help me?
Thank you!! -
@AlganEren You can't write to the characteristic unless there is a client connected. You'll have to store the current connection state and only update the characteristic when you are connected.
-
@jcaron How can I do what you say
Hello! It looks like you're interested in this conversation, but you don't have an account yet.
Getting fed up of having to scroll through the same posts each visit? When you register for an account, you'll always come back to exactly where you were before, and choose to be notified of new replies (either via email, or push notification). You'll also be able to save bookmarks and upvote posts to show your appreciation to other community members.
With your input, this post could be even better 💗
Register Login