Pytrack GPS API
-
@crumble I added a function where i can get time and date. If you want, try it and check if you have any problem.
Code:
## Test code for read date/time from gps and update RTC
import machine
import math
import network
import os
import time
import utime
from machine import RTC
from machine import SD
from machine import Timer
from L76GNSS import L76GNSS
from pytrack import Pytrack
import struct
# setup as a station

import gc

time.sleep(2)
gc.enable()

#Start GPS
py = Pytrack()
l76 = L76GNSS(py, timeout=600)
#start rtc
rtc = machine.RTC()
print('Aquiring GPS signal....')
#try to get gps date to config rtc
while (True):
   gps_datetime = l76.get_datetime()
   #case valid readings
   if gps_datetime[3]:
       day = int(gps_datetime[4][0] + gps_datetime[4][1] )
       month = int(gps_datetime[4][2] + gps_datetime[4][3] )
       year = int('20' + gps_datetime[4][4] + gps_datetime[4][5] )
       hour = int(gps_datetime[2][0] + gps_datetime[2][1] )
       minute = int(gps_datetime[2][2] + gps_datetime[2][3] )
       second = int(gps_datetime[2][4] + gps_datetime[2][5] )
       print("Current location: {}  {} ; Date: {}/{}/{} ; Time: {}:{}:{}".format(gps_datetime[0],gps_datetime[1], day, month, year, hour, minute, second))
       rtc.init( (year, month, day, hour, minute, second, 0, 0))
       break

print('RTC Set from GPS to UTC:', rtc.now())

chrono = Timer.Chrono()
chrono.start()
#sd = SD()
#os.mount(sd, '/sd')
#f = open('/sd/gps-record.txt', 'w')
while (True):

   print("RTC time : {}".format(rtc.now()))
   coord = l76.coordinates()
   #f.write("{} - {}\n".format(coord, rtc.now()))
   print("$GPGLL>> {} - Free Mem: {}".format(coord, gc.mem_free()))
   coord1 = l76.coordinates1()
   print("$GPGGA>> {} - Free Mem: {}".format(coord1, gc.mem_free()))
   coord2 = l76.get_datetime()
   print("$G_RMC>> {} - Free Mem: {}".format(coord2, gc.mem_free()))
The L76GNSS.py code:
from machine import Timer import time import gc import binascii class L76GNSS: GPS_I2CADDR = const(0x10) def __init__(self, pytrack=None, sda='P22', scl='P21', timeout=None): if pytrack is not None: self.i2c = pytrack.i2c else: from machine import I2C self.i2c = I2C(0, mode=I2C.MASTER, pins=(sda, scl)) self.chrono = Timer.Chrono() self.timeout = timeout self.timeout_status = True self.reg = bytearray(1) self.i2c.writeto(GPS_I2CADDR, self.reg) def _read(self): self.reg = self.i2c.readfrom(GPS_I2CADDR, 128) #Changed from 64 to 128 - I2C L76 says it can read till 255 bytes return self.reg def _convert_coords(self, gngll_s): lat = gngll_s[1] lat_d = (float(lat) // 100) + ((float(lat) % 100) / 60) lon = gngll_s[3] lon_d = (float(lon) // 100) + ((float(lon) % 100) / 60) if gngll_s[2] == 'S': lat_d *= -1 if gngll_s[4] == 'W': lon_d *= -1 return(lat_d, lon_d) #diff indexes from original - Using GGA sentence def _convert_coords1(self, gngga_s): lat = gngga_s[2] lat_d = (float(lat) // 100) + ((float(lat) % 100) / 60) lon = gngga_s[4] lon_d = (float(lon) // 100) + ((float(lon) % 100) / 60) if gngga_s[3] == 'S': lat_d *= -1 if gngga_s[5] == 'W': lon_d *= -1 return(lat_d, lon_d) def _get_time(self, gngga_s): gps_time = gngga_s[1] return(gps_time) def _get_altitude(self, gngga_s): gps_altitude = gngga_s[9] return(gps_altitude) def _get_satellites(self, gngga_s): num_satellites = gngga_s[7] return(num_satellites) def _fix_quality(self, gngga_s): valid = gngga_s[6] if valid == '1': return True else: return False #Using RMC sentence def _get_time_rmc(self, gnrmc_s): gps_time = gnrmc_s[1] return(gps_time) def _data_valid_rmc(self, gnrmc_s): valid = gnrmc_s[2] if valid == 'A': return True else: return False def _get_date_rmc(self, gnrmc_s): gps_date = gnrmc_s[9] return(gps_date) def coordinates(self, debug=False): lat_d, lon_d, debug_timeout = None, None, False if self.timeout is not None: self.chrono.reset() self.chrono.start() nmea = b'' while True: if self.timeout is not None and self.chrono.read() >= self.timeout: self.chrono.stop() chrono_timeout = self.chrono.read() self.chrono.reset() self.timeout_status = False debug_timeout = True if not self.timeout_status: gc.collect() break nmea += self._read().lstrip(b'\n\n').rstrip(b'\n\n') gngll_idx = nmea.find(b'GNGLL') if gngll_idx >= 0: gngll = nmea[gngll_idx:] e_idx = gngll.find(b'\r\n') if e_idx >= 0: try: gngll = gngll[:e_idx].decode('ascii') gngll_s = gngll.split(',') lat_d, lon_d = self._convert_coords(gngll_s) except Exception: pass finally: nmea = nmea[(gngll_idx + e_idx):] gc.collect() break else: gc.collect() if len(nmea) > 410: # i suppose it can be safely changed to 82, which is longest NMEA frame nmea = nmea[-5:] # $GNGL without last L time.sleep(0.1) self.timeout_status = True if debug and debug_timeout: print('GPS timed out after %f seconds' % (chrono_timeout)) return(None, None) else: return(lat_d, lon_d) #TEST functions #Parser for GPGGA def coordinates1(self, debug=False): lat_d, lon_d, gps_time, valid, gps_altitude, num_satellites, debug_timeout = None, None, None, None, None, False, False if self.timeout is not None: self.chrono.reset() self.chrono.start() nmea = b'' while True: if self.timeout is not None and self.chrono.read() >= self.timeout: self.chrono.stop() chrono_timeout = self.chrono.read() self.chrono.reset() self.timeout_status = False debug_timeout = True if not self.timeout_status: gc.collect() break nmea += self._read().lstrip(b'\n\n').rstrip(b'\n\n') gpgga_idx = nmea.find(b'GPGGA') if gpgga_idx >= 0: gpgga = nmea[gpgga_idx:] gpgga_e_idx = gpgga.find(b'\r\n') if gpgga_e_idx >= 0: try: gpgga = gpgga[:gpgga_e_idx].decode('ascii') gpgga_s = gpgga.split(',') lat_d, lon_d = self._convert_coords1(gpgga_s) gps_time = self._get_time(gpgga_s) valid = self._fix_quality(gpgga_s) gps_altitude = self._get_altitude(gpgga_s) num_satellites = self._get_satellites(gpgga_s) except Exception: pass finally: nmea = nmea[(gpgga_idx + gpgga_e_idx):] gc.collect() break else: gc.collect() if len(nmea) > 410: # i suppose it can be safely changed to 82, which is longest NMEA frame nmea = nmea[-5:] # $GNGL without last L time.sleep(0.1) self.timeout_status = True if debug and debug_timeout: print('GPS timed out after %f seconds' % (chrono_timeout)) return(None, None, None, None, False, None) else: return(lat_d, lon_d, gps_time, gps_altitude, valid, num_satellites) #parser for UTC time and date >> Reads GPRMC def get_datetime(self, debug=False): lat_d, lon_d, gps_time, valid, gps_date, rmc_idx, debug_timeout = None, None, None, None, None, -1, False if self.timeout is not None: self.chrono.reset() self.chrono.start() nmea = b'' while True: if self.timeout is not None and self.chrono.read() >= self.timeout: self.chrono.stop() chrono_timeout = self.chrono.read() self.chrono.reset() self.timeout_status = False debug_timeout = True if not self.timeout_status: gc.collect() break nmea += self._read().lstrip(b'\n\n').rstrip(b'\n\n') #Since or spg or glonass could give date see which one is present -SEE page 10 GNSS protocol #GPS only - GPRMC GPGGA #Glonass only - GNRMC GPGGA #GPS+GLON - GNRMC GPGGA #No station - GPRMC GPGGA gprmc_idx = nmea.find(b'GPRMC') gnrmc_idx = nmea.find(b'GNRMC') if gprmc_idx >= 0: rmc_idx = gprmc_idx if gnrmc_idx >= 0: rmc_idx = gnrmc_idx if rmc_idx >= 0: rmc = nmea[rmc_idx:] rmc_e_idx = rmc.find(b'\r\n') if rmc_e_idx >= 0: try: rmc = rmc[:rmc_e_idx].decode('ascii') rmc_s = rmc.split(',') lat_d, lon_d = self._convert_coords1(rmc_s[1:]) gps_time = self._get_time_rmc(rmc_s) valid = self._data_valid_rmc(rmc_s) gps_date = self._get_date_rmc(rmc_s) except Exception: pass finally: nmea = nmea[(rmc_idx + rmc_e_idx):] gc.collect() break else: gc.collect() if len(nmea) > 512: # i suppose it can be safely changed to 82, which is longest NMEA frame --CHANGED to 512 nmea = nmea[-5:] # $GNGL without last L time.sleep(0.1) self.timeout_status = True if debug and debug_timeout: print('GPS timed out after %f seconds' % (chrono_timeout)) return(None, None, None, False, None) else: return(lat_d, lon_d, gps_time, valid, gps_date) -
@andrethemac Yeah, ran into that issue aswell.
why we are re-doing the gps library that comes from pycom :)
and selectively adding more and more features ... so we won't run out of memory
-
@neuromystix I used to search the nmea messages with _read looking for xxGGA until a fix was found. Only then I use the l76.coordinates to find the exact position.
a bit of a work around.
The new library you posted works as a charm, no more memory errors.
The Quectel is a bit "slow" but with a timeout of 180 (3 minutes), I manage to get a fix (almost) every time the wipy/lopy comes awake (after deep sleep). Not so good for the battery, 3 minutes on +- 70 mA vs 390 uA in deep sleep with the pytrack. The 390 uA are probably from the accelerator, I use the accelerator to wake up the unit when it gets more than 2g for over a second. -
@andrethemac i followed the original lib which use gc to clean memory. But haven't tried any other options.
Same problem here with the starting time. Sometimes i just unplug the cable from my computer and plug it to a powerbank and have to wait 5 minutes for it to get fix. For my project this will not be a problem but for a battery operated device it's not a good thing... -
@neuromystix Works like a champ - it would be good if this was added to the main lib. I added HDOP (GPGGA) as that is a good indication of accuracy.
-
@neuromystix your work has been awesome. Thank you so much for your efforts. In running some test logs earlier today, I found that I got a series of fixes logged that were "invalid". Upon reviewing you code the protocol documents, I have one update to propose
def _fix_quality(self, gngga_s):
    valid = gngga_s[6]
    if valid == '0':
        return False
    else:
        return True
Your initial fix quality function only returned true if gngga_s[6] was 1, however it seems that values such as 2 or 3 may be valid as well.
Per v2.2 of the protocol spec:
Value Description
0 Fix not available or invalid
1 GPS SPS Mode, fix valid
2 Differential GPS, SPS Mode, fix valid
3 GPS PPS Mode, fix validOnce again, thanks for your efforts. Just wanted to share my findings.
-
@mwtidd When i wrote it i was reading the "Quectel l76 Series GNSS protocol Specification V3.3" which says (@page 12):
Fix Status
"0"=Invalid
"1"=GNSS fix
"2"=DGPS fix
"6"=Estimated (dead reckoning) modeThat's why i only used "1". But even with that, we can use the value "2" for the DGPS fix. I haven´t checked if i had some fixes "2" ou another values. If it worked for you, nice ;)
Best regards
Nelson Pinto -
@bmarkus said in Pytrack GPS API:
umber of satellites visible /used for fi
- number of satellites visible /used for fix - Is this possible yet?!
-
@stefan85e If you need the number of satellites used to fix, it's already parsed in l76.coordinates1(). The "Satellites in view" i haven't done it, but it's easy to implement, just parse any $__GSV sentence, the third field is "Satellites in view".
-
-
Hi all. I've taken the original librarya and @Neuromystix addtions and made my own library. It parses aml the sentences from the L76 gps and returns them as a dict. you can get the coordinates parsed, the time, ...
https://github.com/andrethemac/L76GLNSV4I've noticed one (strange?) thing. the RMC (required minimum data to get a fix) message only pass once (just after starting the gps) and does not reappear. Any idea's ?
best regards -
@neuromystix said in Pytrack GPS API:
For use it just call l76.coordinates1() which will return (lat, long, time(not formatted), altitude (M), valid fix (true ou false), number of satellites).
L76GNSS.py
So what did you do to get the nimber of satellites? We are trying this and we cant get it to work. -
@stefan85e Hello,
You have to do something like this inside your code, and you'll get the number of satellites used for fix:
...
gps_data = l76.coordinates1()
n_sat = gps_data[5]
...
Or you can use the @andrethemac library which will get you all the data ;)
-
@andrethemac
(2018, 4, 17, 11, 29, 12, 564887, None)(None(53.33632, 12.53262)
(None, None) Got when I add this:gps_data = l76.coordinates1()
n_sat = gps_data[5]Did also try to use this lib:
https://github.com/andrethemac/L76GLNSV4 -
@neuromystix said in Pytrack GPS API:
num_satellites
Does this work:
return(lat_d, lon_d, gps_time, gps_altitude, valid, num_satellites)
I want num_satellites...
-
@stefan85e If you are using my code (and just my code, not the one from @andrethemac), when you call gps_data = l76.coordinates1() it will return a list gps_data with latitude at first position (gps_data[0]), longitude at second (gps_data[1]), and so on till the sixth position where you get the number of satellites (gps_data[5]). So, number_of_satellites = gps_data[5].
-
@stefan85e An example on how to get the number of satelites with my library
from pytrack import Pytrack from L76GNSV4 import L76GNSS py = Pytrack() L76 = L76GNSS(pytrack=py) print("test L76") # returns the info about sattelites in view at this moment # even without the gps being fixed print(L76.gps_message('GSV')) # returns the number of sattelites in view at this moment # even without the gps being fixed print(L76.gps_message('GGA')['NumberOfSV']) # returns the coordinates # with debug true you see the messages parsed by the # library until you get a the gps is fixed print(L76.coordinates(debug=True)) #L76.getUTCDateTime(debug=True) #L76._read_message(debug=True) -
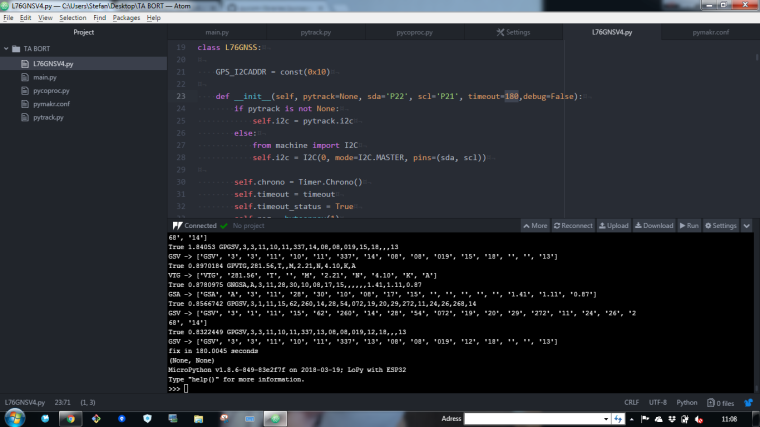
Got this
I see that you have a 180 timeout in the code:
-> L76GNSV4 - So how do I know how many sattelites i have then :) just so I look at right nr :)
´´´´
def init(self, pytrack=None, sda='P22', scl='P21', timeout=180,debug=False):
´´´´ -
@stefan85e The timeout is to prevent the library to wait for ever. 180 seconds (3 minutes) is (for me) most of the time enough to get a fixed location. (that is after a cold start)
the GGA sentences contains the number of messages seen by the GPS, In the dict that GGA returns, this is the "NumberOfSV' fied.
with this you get this number -> L76.gps_message('GGA')['NumberOfSV']
In your screenshot the line that prints the number of satellites has scrolled out of view
but if you make this line the last you get the number:
print(L76.gps_message('GGA')['NumberOfSV'])
or remove the 'debug=True) from the coordinates line (the debug spews out a lot of information)
I'm still working on the library to make it faster
best regards -
@andrethemac published a new version of the Library to github
https://github.com/andrethemac/L76GLNSV4If you find some errors or have a request, please ask.
best regards
Hello! It looks like you're interested in this conversation, but you don't have an account yet.
Getting fed up of having to scroll through the same posts each visit? When you register for an account, you'll always come back to exactly where you were before, and choose to be notified of new replies (either via email, or push notification). You'll also be able to save bookmarks and upvote posts to show your appreciation to other community members.
With your input, this post could be even better 💗
Register Login