Welcome to the Pycom forum Forum
    • \[\[global:header.categories\]\]
    • \[\[global:header.recent\]\]
    • \[\[global:header.tags\]\]
    • \[\[global:header.popular\]\]
    • Login

    Explore Pybytes | Official Documentation | Report a Firmware Bug/Issue | GitHub

    Lopy with pytrack, how connect/use GPS?

    Scheduled Pinned Locked Moved LoPy
    gpslopypytrack
    76 Posts 5 Posters 33.6k Views 5 Watching
    Loading More Posts
    • Oldest to Newest
    • Newest to Oldest
    • Most Votes
    Reply
    • Reply as topic
    Log in to reply
    This topic has been deleted. Only users with topic management privileges can see it.
    • L Offline
      livius @zceld
      last edited by

      @zceld
      0_1516291674076_70f8f1fd-c46e-4ca8-87d2-e34858750cce-image.png

      think about people first, then computers

      Z 1 Reply Last reply Reply Quote 0
      • Z Offline
        zceld @livius
        last edited by

        @livius

        Perfect!. working correctly again. I do not understand how a tabulation can give an error. XDD it shows that I am new? Thank you very much again, although I'll probably come back with something else. But good Thanks to your patience as always.

        Z 1 Reply Last reply Reply Quote 0
        • C Offline
          crumble @zceld
          last edited by

          @zceld

          Is there anything I can do ?

          You can try to call the garbage collector before and after you read the coordinates.

          The better solution. Implement the GPS stuff by your own and share the code with us. You have to read the stream from the GPS chip into fix allocated buffers and parse them by your own. If you need only the coordinates, it is simple, you will need around 100 lines of code. I stuck with my version :-(. Had no time to work on it.

          L 1 Reply Last reply Reply Quote 0
          • Z Offline
            zceld @zceld
            last edited by

            @livius
            Well, I have another doubt. I am trying to send the coordinates by LoRa and it gives me the following problem that I do not know how to solve.
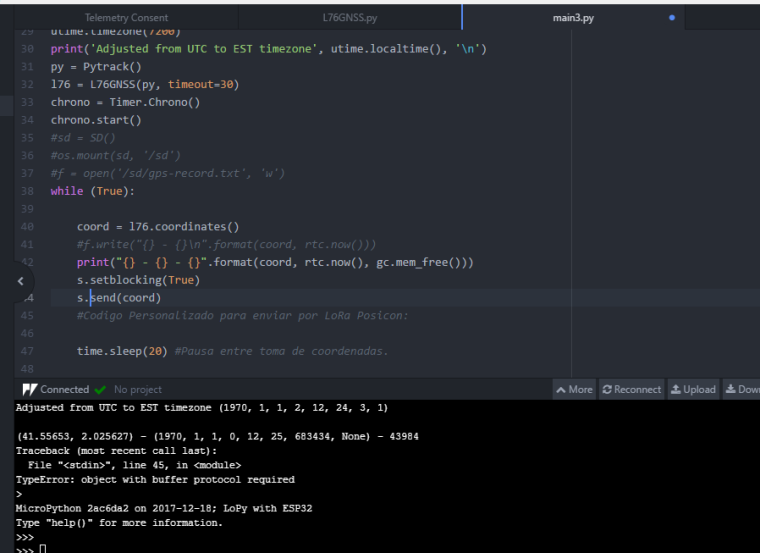
            0_1516292916315_6.PNG

            Other questions more:

            print("{} - {} - {}".format(coord, rtc.now(), gc.mem_free()))
            

            This returns (latitude, longitude) - (Real time clock) - free ram
            But and the altitude?
            The time can be updated?

            L C 2 Replies Last reply Reply Quote 0
            • L Offline
              livius @zceld
              last edited by livius

              @zceld said in Lopy with pytrack, how connect/use GPS?:
              touple is not buffered
              you need bytes you can try to cast this as bytes() but for lora better is using pack.
              look at samples about lora in official docs https://docs.pycom.io/

              Time you can update from wifi connection
              by e.g.

              rtc.ntp_sync("pool.ntp.org")
              

              or retrive it from GPS
              or some external device for DCF or MSF

              think about people first, then computers

              1 Reply Last reply Reply Quote 0
              • C Offline
                crumble @zceld
                last edited by

                @zceld

                But and the altitude?
                The time can be updated?

                If you look into the code of the library you will see, that only the coordinates are read from the GPS. No altitude and no dateTime.

                The time information is read from WiFi. You will need access to an NTP server.

                The sentence which is used to get the coordinates contains the time as well, but not the date. If you need only the time, you can simply add this to the library.

                For date and time you have to add support for parsing additional NMEA sentences.

                1 Reply Last reply Reply Quote 0
                • L Offline
                  livius @crumble
                  last edited by

                  @crumble
                  better use existing one
                  https://github.com/livius2/micropyGPS
                  and exctend it if needed

                  think about people first, then computers

                  Z 1 Reply Last reply Reply Quote 0
                  • Z Offline
                    zceld @livius
                    last edited by

                    @livius
                    Thank you very much for the recommendation but using 'microGPS' gives me a lack of memory again.
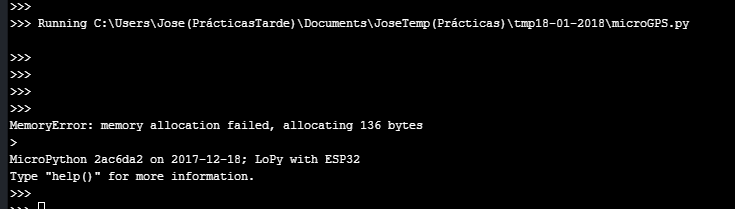
                    0_1516633835702_7.PNG

                    On the other hand I do not know if to take advantage of this post or open another one. It is on the subject LoRa that I do not understand very well the programming examples. I am using this one.

                    Using a board in sending mode, and another in receiver mode, I do not understand why there are messages sent by LoRa that are lost or not picked up by the receiver.
                    This captur reciver:
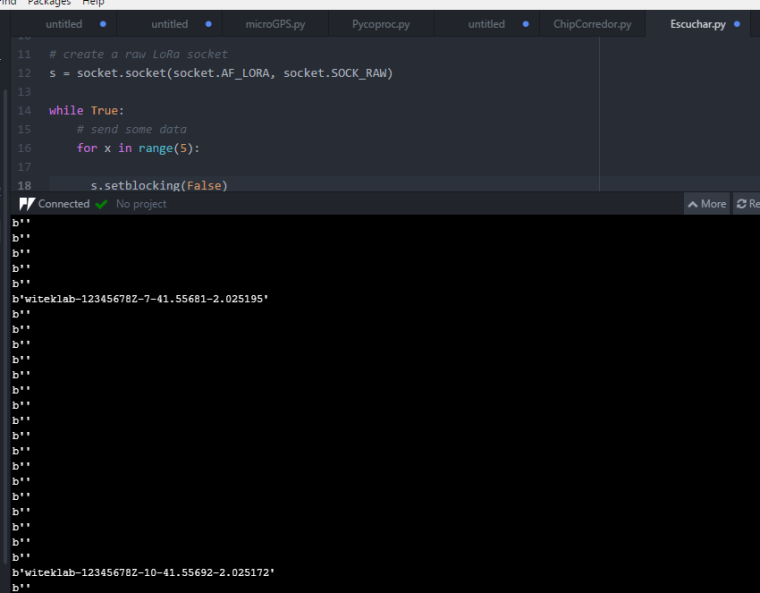
                    0_1516634446145_8.PNG

                    transmitter:0_1516634503753_9.PNG
                    print:
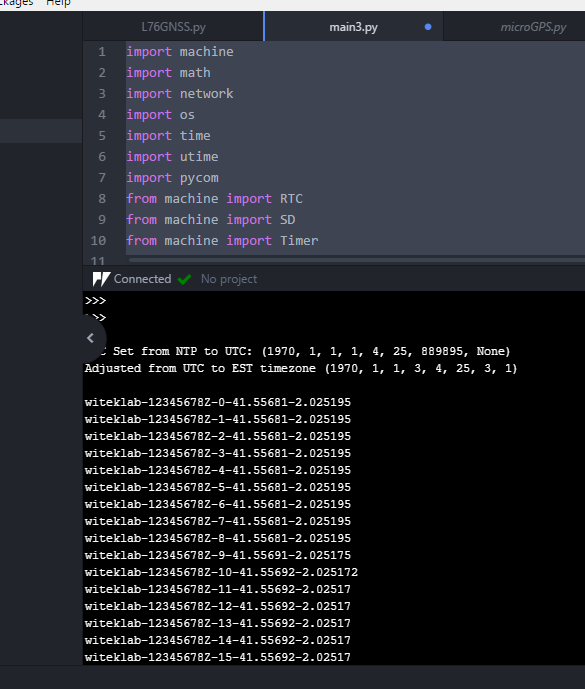
                    identifier-identifier-counter-longitude-latitude

                    As you can see in the image of the receiver, it goes from counter 7 to 10 and has lost message 8 and 9

                    • issuer code:
                    import machine
                    import math
                    import network
                    import os
                    import time
                    import utime
                    import pycom
                    from machine import RTC
                    from machine import SD
                    from machine import Timer
                    from L76GNSS import L76GNSS
                    from pytrack import Pytrack
                    
                    from network import LoRa
                    import socket                                                                 
                    lora = LoRa(mode=LoRa.LORA)                                                  
                    s = socket.socket(socket.AF_LORA, socket.SOCK_RAW)                   
                    # setup as a station
                    
                    import gc
                    
                    time.sleep(2)
                    gc.enable()
                    
                    # setup rtc
                    rtc = machine.RTC()
                    rtc.ntp_sync("pool.ntp.org")
                    utime.sleep_ms(750)
                    print('\nRTC Set from NTP to UTC:', rtc.now())
                    utime.timezone(7200)
                    print('Adjusted from UTC to EST timezone', utime.localtime(), '\n')
                    py = Pytrack()
                    l76 = L76GNSS(py, timeout=30)
                    chrono = Timer.Chrono()
                    chrono.start()
                    j=0 #accountant
                    while (True):
                    
                        coord = l76.coordinates()
                    
                        #Codigo Personalizado para enviar por LoRa Posicon:
                        x = "witeklab-"+"12345678Z-"+str(j)+"-"+str(coord[0]) + "-"+str(coord[1])
                        s.setblocking(True)
                        s.send(x)
                        print(x)
                        time.sleep(2) #Pausa entre toma de coordenadas.
                        j=1+j
                    

                    receiver code:

                    from network import LoRa
                    import socket
                    import machine
                    import time
                    import pycom
                    
                    # initialize LoRa in LORA mode
                    # more params can also be given, like frequency, tx power and spreading factor
                    lora = LoRa(mode=LoRa.LORA)
                    
                    # create a raw LoRa socket
                    s = socket.socket(socket.AF_LORA, socket.SOCK_RAW)
                    
                    while True:
                        # send some data
                        for x in range(5):
                    
                          s.setblocking(False)
                          data = s.recv(64)
                          time.sleep(0.1)
                          print(data)
                    C L 2 Replies Last reply Reply Quote 0
                    • C Offline
                      crumble @zceld
                      last edited by

                      @zceld LoRa is like a radio in citizen band. Anyone can send messages around and all have to listen to them. So you may receive data from other devices as well.

                      Too solve your specific problem you shall set in your receiver blocking to true. This will wait until you reveived a message. If it is false it will not wait to receive a message in line `data = s.recv(64)
                      So it will continue with an empty string, because it has not received a message.

                      Setting blocking mode to false is useful, if you want to run your loop until you received a certain message. Setting it to true is useful if you want to start the loop after you received a message.

                      If you have only nonblocking calls and you want to wait for a message, you have to call it in a loop until something receives. This will need a lot of battery power.

                      If you want to run a loop until you receive a certain message and you have only blocking calls, you have to use multi threading to solve this problem. This will not consume much battery power, but it makes your code more complex.

                      Z 1 Reply Last reply Reply Quote 0
                      • L Offline
                        livius @zceld
                        last edited by

                        @zceld said in Lopy with pytrack, how connect/use GPS?:

                        Thank you very much for the recommendation but using 'microGPS' gives me a lack of memory again.

                        When and where do you create microGPS object instance?

                        think about people first, then computers

                        Z 1 Reply Last reply Reply Quote 0
                        • Z Offline
                          zceld @crumble
                          last edited by zceld

                          @crumble
                          I am very interested in what you say, because what really interests me is that the Lora system is in a listening mode until I receive a message, when we receive a message we can do something specific.

                          So a possible solution would be changing s.setblocking (True) like this?:

                          from network import LoRa
                          import socket
                          import machine
                          import time
                          import os
                          import pycom
                          
                          lora = LoRa(mode=LoRa.LORA)
                          
                          while True:
                                s.setblocking(True)
                                data = s.recv(64) 
                                print(data)
                          
                          C 1 Reply Last reply Reply Quote 0
                          • Z Offline
                            zceld @livius
                            last edited by

                            @livius

                            Well no, I just ran microGPS as if it were the main. So you want to say that microGPS is a library and that to give me the coordinates I should develop a code like this one but with the library 'microGPS'?

                            Example code:

                            import machine
                            import math
                            import network
                            import os
                            import time
                            import utime
                            import pycom
                            from machine import RTC
                            from machine import SD
                            from machine import Timer
                            from L76GNSS import L76GNSS
                            from pytrack import Pytrack
                            #send with LoRa:
                            from network import LoRa
                            import socket                                                    
                            lora = LoRa(mode=LoRa.LORA)                                                  
                            s = socket.socket(socket.AF_LORA, socket.SOCK_RAW)                
                            
                            # setup as a station
                            import gc
                            gc.enable()
                            
                            # setup rtc
                            rtc = machine.RTC()
                            rtc.ntp_sync("pool.ntp.org")
                            utime.sleep_ms(750)
                            print('\nRTC Set from NTP to UTC:', rtc.now())
                            utime.timezone(7200)
                            print('Adjusted from UTC to EST timezone', utime.localtime(), '\n')
                            py = Pytrack()
                            l76 = L76GNSS(py, timeout=30)
                            chrono = Timer.Chrono()
                            chrono.start()
                            
                            while (True):
                            
                                coord = l76.coordinates()
                            
                            1 Reply Last reply Reply Quote 0
                            • C Offline
                              crumble @zceld
                              last edited by

                              @zceld said in Lopy with pytrack, how connect/use GPS?:

                              So a possible solution would be changing s.setblocking (True) like this?:

                              Yes. You need to set it only once outside the loop:

                              s = socket.socket(socket.AF_LORA, socket.SOCK_RAW)
                              s.setblocking(True)
                              while True:
                                 data = s.recv(64) 
                                 print(data)
                              
                              Z 1 Reply Last reply Reply Quote 0
                              • Z Offline
                                zceld @crumble
                                last edited by

                                @crumble

                                Great! thank you very much. Now I just need to be able to connect via Wi-Fi directly to Lopy, I do not know what the password is:
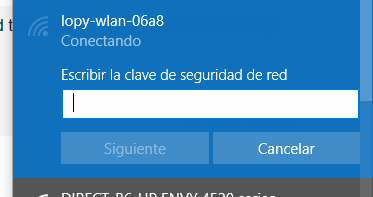
                                0_1516721750191_10.PNG

                                C 1 Reply Last reply Reply Quote 0
                                • C Offline
                                  crumble @zceld
                                  last edited by

                                  @zceld

                                  here you will find the passowrd

                                  https://docs.pycom.io/chapter/toolsandfeatures/repl/telnet.html

                                  Z 1 Reply Last reply Reply Quote 0
                                  • Z Offline
                                    zceld
                                    last edited by zceld

                                    good morning everyone

                                    I already have a question in the ink, I've been looking and I have not seen anything clear about the plate. Therefore I take my post of doubts.

                                    Someone could explain to me what changes if you have write the function:

                                    s.setblocking (True)
                                    #or
                                    s.setblocking (False)
                                    
                                    ??
                                    

                                    Thanks, greetings in advance!

                                    By the way, I already managed to connect via wifi @crumble

                                    1 Reply Last reply Reply Quote 0
                                    • Z Offline
                                      zceld
                                      last edited by zceld

                                      On the other hand, I have the insecurity that I never know how long it will take to find GPS the pytrack ... sometimes they connect in 2 minutes, other times in 15 and then cases like today that I have been without signal for the whole afternoon...

                                      Code:

                                      import machine
                                      import math
                                      import network
                                      import os
                                      import time
                                      import utime
                                      import pycom
                                      from machine import RTC
                                      from machine import SD
                                      from machine import Timer
                                      from L76GNSS import L76GNSS
                                      from pytrack import Pytrack
                                      #send with LoRa:
                                      from network import LoRa
                                      import socket                                                    
                                      lora = LoRa(mode=LoRa.LORA)                                                  
                                      s = socket.socket(socket.AF_LORA, socket.SOCK_RAW)                
                                      
                                      # setup as a station
                                      import gc
                                      gc.enable()
                                      
                                      # setup rtc
                                      rtc = machine.RTC()
                                      rtc.ntp_sync("pool.ntp.org")
                                      utime.sleep_ms(750)
                                      print('\nRTC Set from NTP to UTC:', rtc.now())
                                      utime.timezone(7200)
                                      print('Adjusted from UTC to EST timezone', utime.localtime(), '\n')
                                      py = Pytrack()
                                      l76 = L76GNSS(py, timeout=30)
                                      chrono = Timer.Chrono()
                                      chrono.start()
                                      
                                      while (True):
                                      
                                          coord = l76.coordinates()                     
                                      

                                      Result:
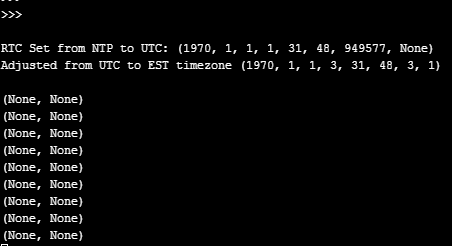
                                      0_1516899221556_123.PNG

                                      0_1516901169824_1.PNG

                                      C 1 Reply Last reply Reply Quote 0
                                      • C Offline
                                        crumble @zceld
                                        last edited by

                                        @zceld You are inside a building, right? In this case you are lucky, that you receive enough signals. So bad weather conditions, more people in the floors above you, other radio signals, other set of satalites visible for your device, will influence, if you get a signal.

                                        Without an external antenna you have to ways to solve this problem.

                                        1. Move the device to a place with better signal quality
                                        2. Add a layer to your program, so you can choose between real sensor data and test data.

                                        Or try a soft reboot (ctrl-d). The last time I tested it, the GPS chip got a fix after reboot. Maybe it was only a coincidence ;)

                                        Z 1 Reply Last reply Reply Quote 0
                                        • Z Offline
                                          zceld @crumble
                                          last edited by

                                          @crumble
                                          If in it is quite unlikely to get a good signal inside a building, in fact with the smartphone many times it is not able to catch coverage. But since the LoPy with the Pytrack has always ended up taking me, it was strange to me that today I do not.

                                          I tried the ctrl + d but it has not had an effect. Thank you very much for the info.

                                          On the subject of :
                                          s.setblocking (True)
                                          #or
                                          s.setblocking (False)

                                          would you explain to me how it works?
                                          I have done these tests but they do not convince me:

                                          while (True):
                                              s.setblocking(True)
                                              coord = l76.coordinates()
                                          
                                              x = "hi-"+str(j)+"-"+"12345678Z-"+str(coord[0]) + "-"+str(coord[1])
                                              p = str(coord[0])
                                              if p =='None':
                                                  pycom.rgbled(0x7f0000)
                                                  time.sleep(0.5)
                                                  pycom.heartbeat(False)
                                                  print("Buscando -",nintentos)
                                                  nintentos+=1
                                              else:
                                                  s.send(x)
                                                  pycom.rgbled(0xfffe02)
                                                  time.sleep(0.1)
                                                  pycom.heartbeat(False)
                                                  print(x)
                                                  j+=1    
                                                  time.sleep(20) #Pausa entre toma de coordenadas.
                                          
                                          
                                              alertas=[]
                                              s.setblocking(False)
                                              data = s.recv(64)
                                              time.sleep(3) 


                                              ide =data.decode("utf-8")  
                                              ide = ide.split('-')
                                              if ide[0] == 'alerta':
                                                  for x in range (1,3):
                                                      pycom.rgbled(0xC011EB)#Lila  
                                                      time.sleep(0.1)  
                                                      pycom.heartbeat(False)
                                                      time.sleep(0.1) 
                                                  if ide[1] not in alertas:
                                                      alertas.append(ide[1])
                                                      for x in range (1,3):
                                                          pycom.rgbled(0x0007F)#Azul
                                                          time.sleep(1)
                                                          pycom.heartbeat(False)
                                                          time.sleep(0.1)


                                          The idea of operation is that every 20 seconds approximately, make one get the GPS position and send it by LoRa.

                                          time.sleep(20)
                                          

                                          Done that you hear if you are sending a message then I put s.setblocking (False) that I understand that in this mode will listen for 3 seconds:

                                              alertas=[]
                                              s.setblocking(False)
                                              data = s.recv(64)
                                              time.sleep(3) 
                                          

                                          Surely you have a better approach to programming or a different method, and that is what I have been able to do with what I think each command s.setblocking () does

                                          C 1 Reply Last reply Reply Quote 0
                                          • C Offline
                                            crumble @zceld
                                            last edited by crumble

                                            @zceld

                                            If you have something like

                                            while True:
                                                result = s.recv(256)
                                                print(result)
                                            

                                            and you run it in setblocking(True) mode, the program will wait on the line result = s.resv(256) until it received a message and will then continue. So result will always contains someting you received from the aether. Either from your LoPy or another device. So you shall not forget to check the content before controling some other hardware like servos, etc.

                                            if you run the same loop with setblocking(False) it will not wait. It will directly go to the next line. So you will most of the time get your empty lines, because no one has send someting.

                                            You can use this for easy control your program. If you want to open a door when someone sends a message you will use setblocking(True)

                                            s.setblocking(True)
                                            while True:
                                                result = s.recv(256)
                                                if result.equals('Open door'):
                                                     OpenTheDoor()
                                            

                                            If you use this with setblocking(False) it will not be that dangerous, because the if guards the door unless someone sends the right message. But it will use a lot of power, because it will run the loop without any pause. This can be really bad, if you run your device by battery. So you may have to charge your device every day instead of once a week,

                                            If you want to stop something when someone sends you a stop message you would to something like this:

                                            s.setblocking(False)
                                            stopMessage = ''
                                            while stopMessage != 'stop'
                                                toggleLED()
                                                stopMessage = s.recv(256)
                                            

                                            setblocking(True) would be a bad idea, becaus the recv call would wait until someone sends a message. So your LED would change only its state when someone is sending a messages. With setblocking(False) you will see it blinking until someone sends the right message.
                                            Z 1 Reply Last reply Reply Quote 0

                                            Hello! It looks like you're interested in this conversation, but you don't have an account yet.

                                            Getting fed up of having to scroll through the same posts each visit? When you register for an account, you'll always come back to exactly where you were before, and choose to be notified of new replies (either via email, or push notification). You'll also be able to save bookmarks and upvote posts to show your appreciation to other community members.

                                            With your input, this post could be even better 💗

                                            Register Login
                                            • 1
                                            • 2
                                            • 3
                                            • 4
                                            • 3 / 4
                                            • First post
                                              Last post

                                            Pycom on Twitter

                                            Pycom